0x00b20000
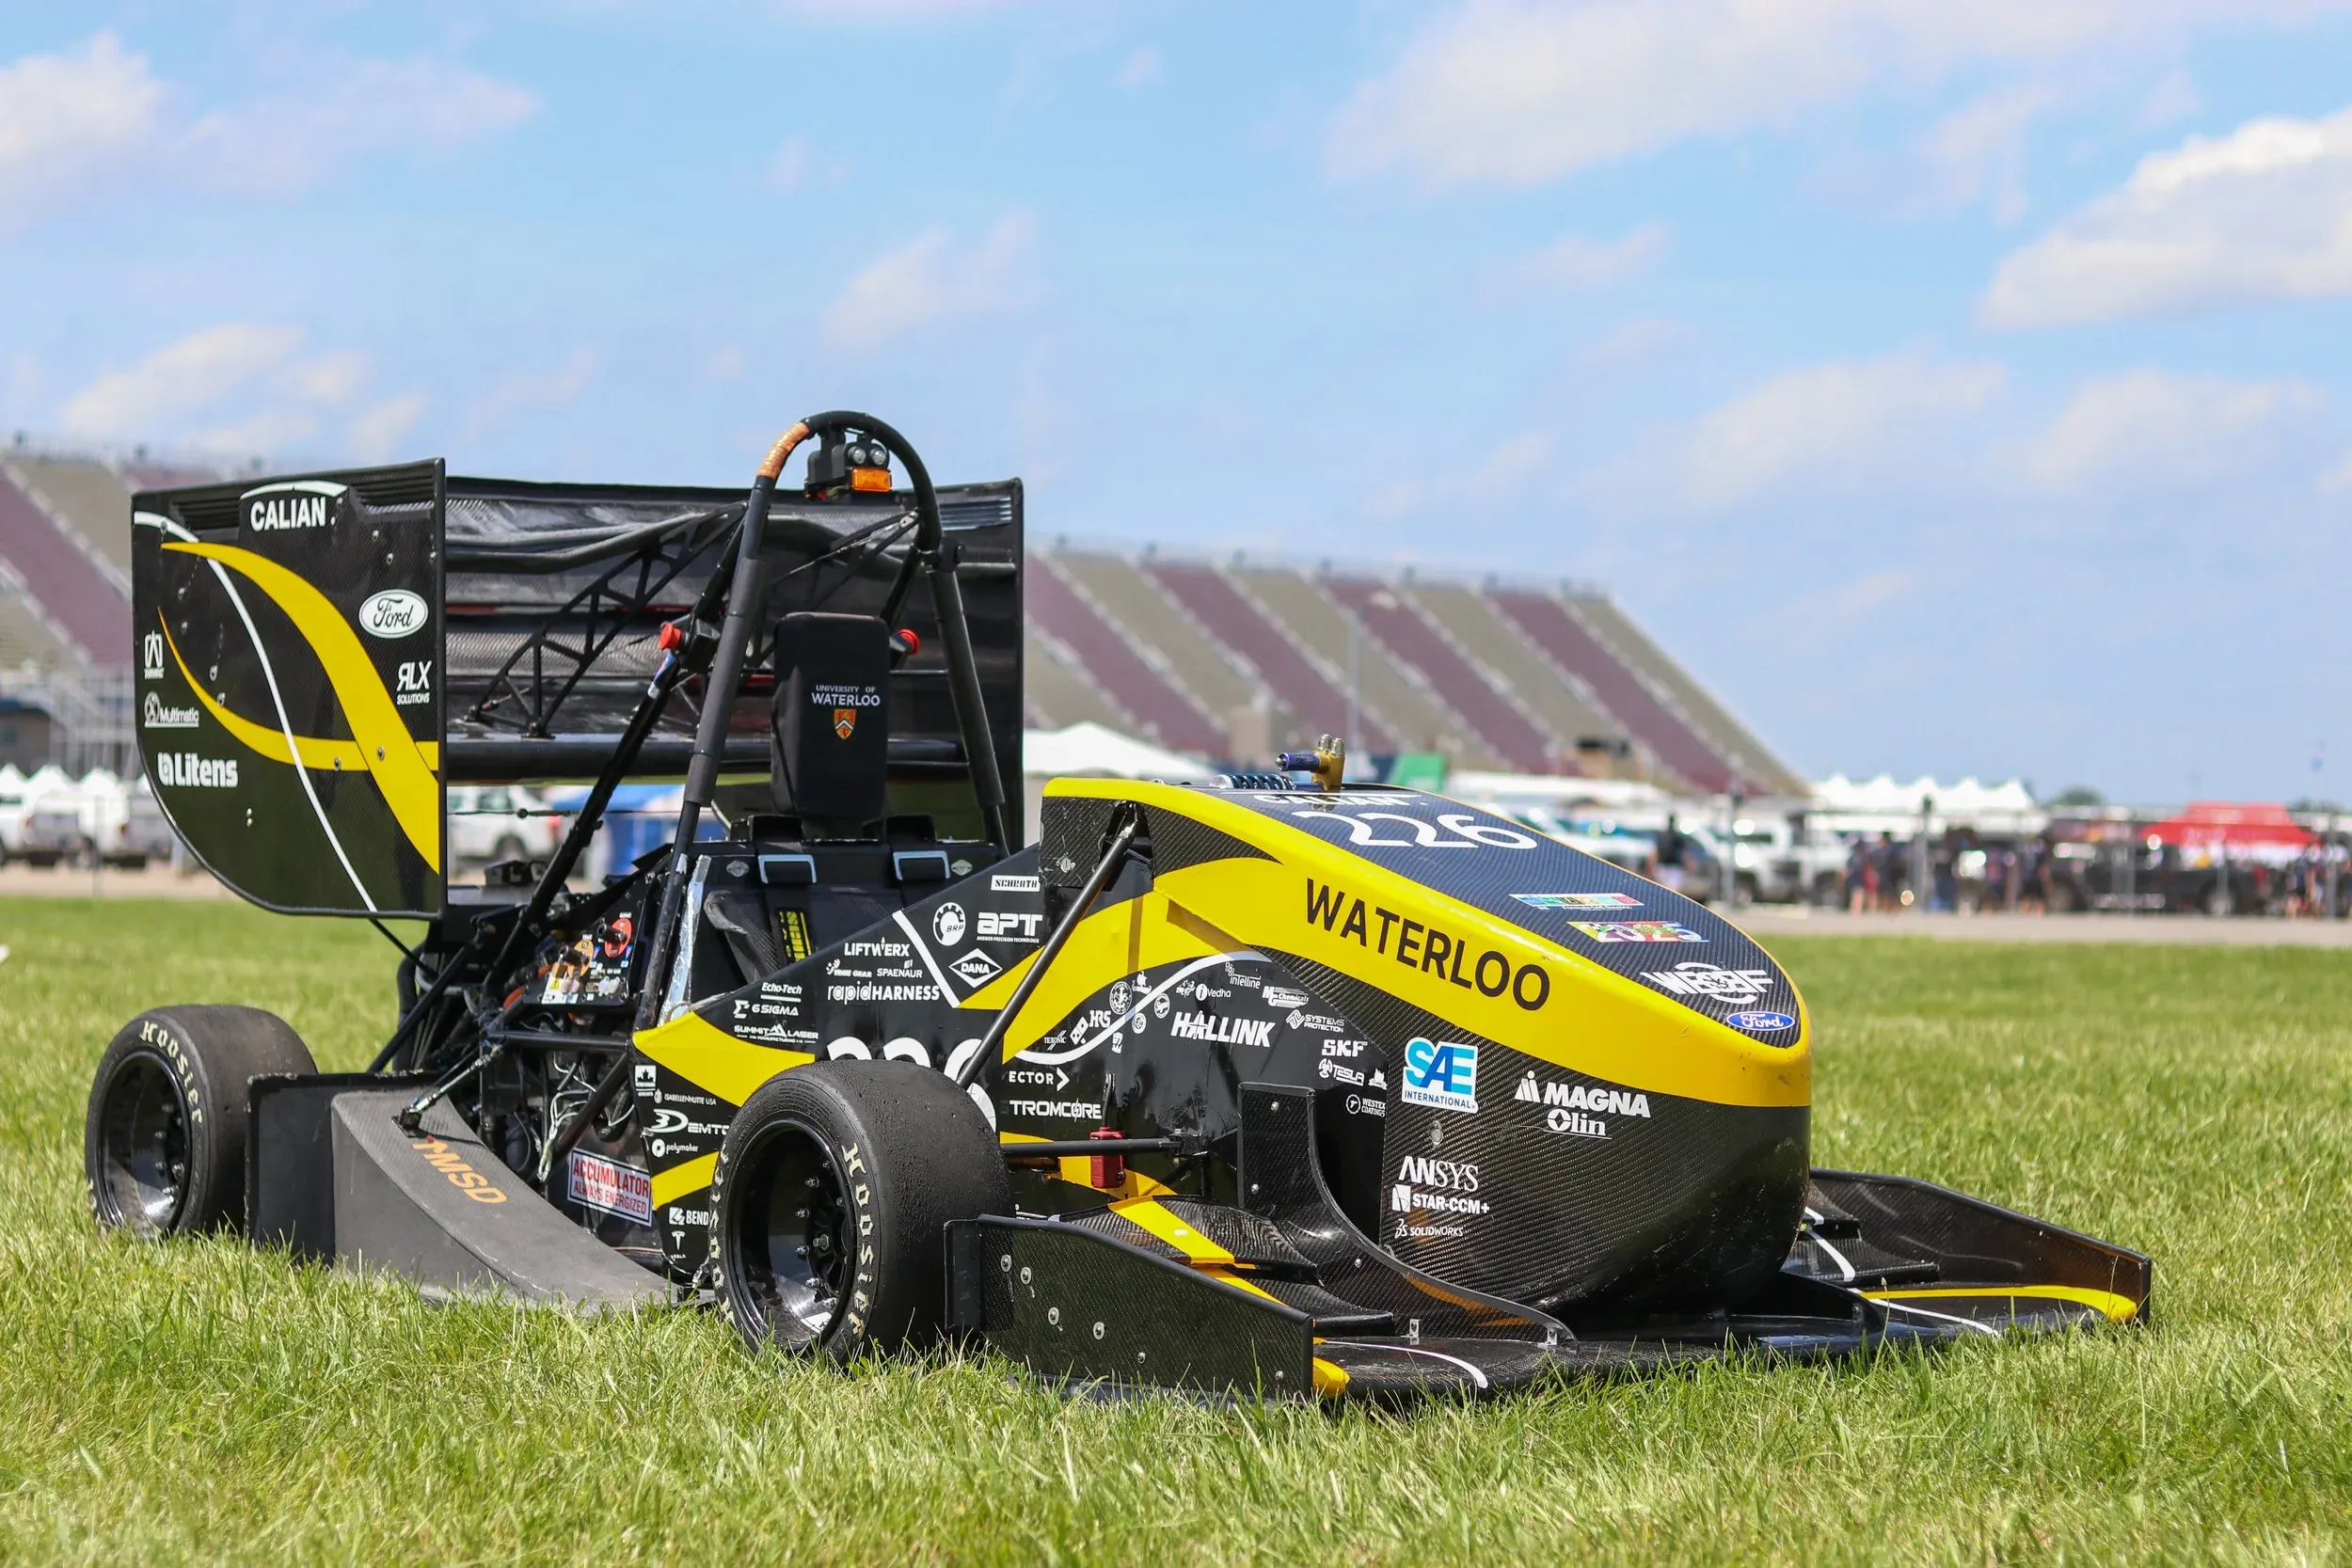
UW Formula Electric
Software for a student-built electric race car, developing both onboard and ancillary systems.
- better state-of-charge accuracy
- +70%
Charging control daemon (in progress)
A Linux daemon that controls charging the car and reports battery telemetry.
PDU charger firmware (in progress)
Bring-up of the charger IC on the PDU, which charges the LV battery from the HV pack through a DC-DC.
State of charge
Deployed an adaptive Unscented Kalman Filter in C, replacing the lookup table the car used before.
Voltage control
Wrote the voltage control driver for an STM32 under FreeRTOS, communicating with peripherals over SPI and UART.